Vex Sonar Sensor Code
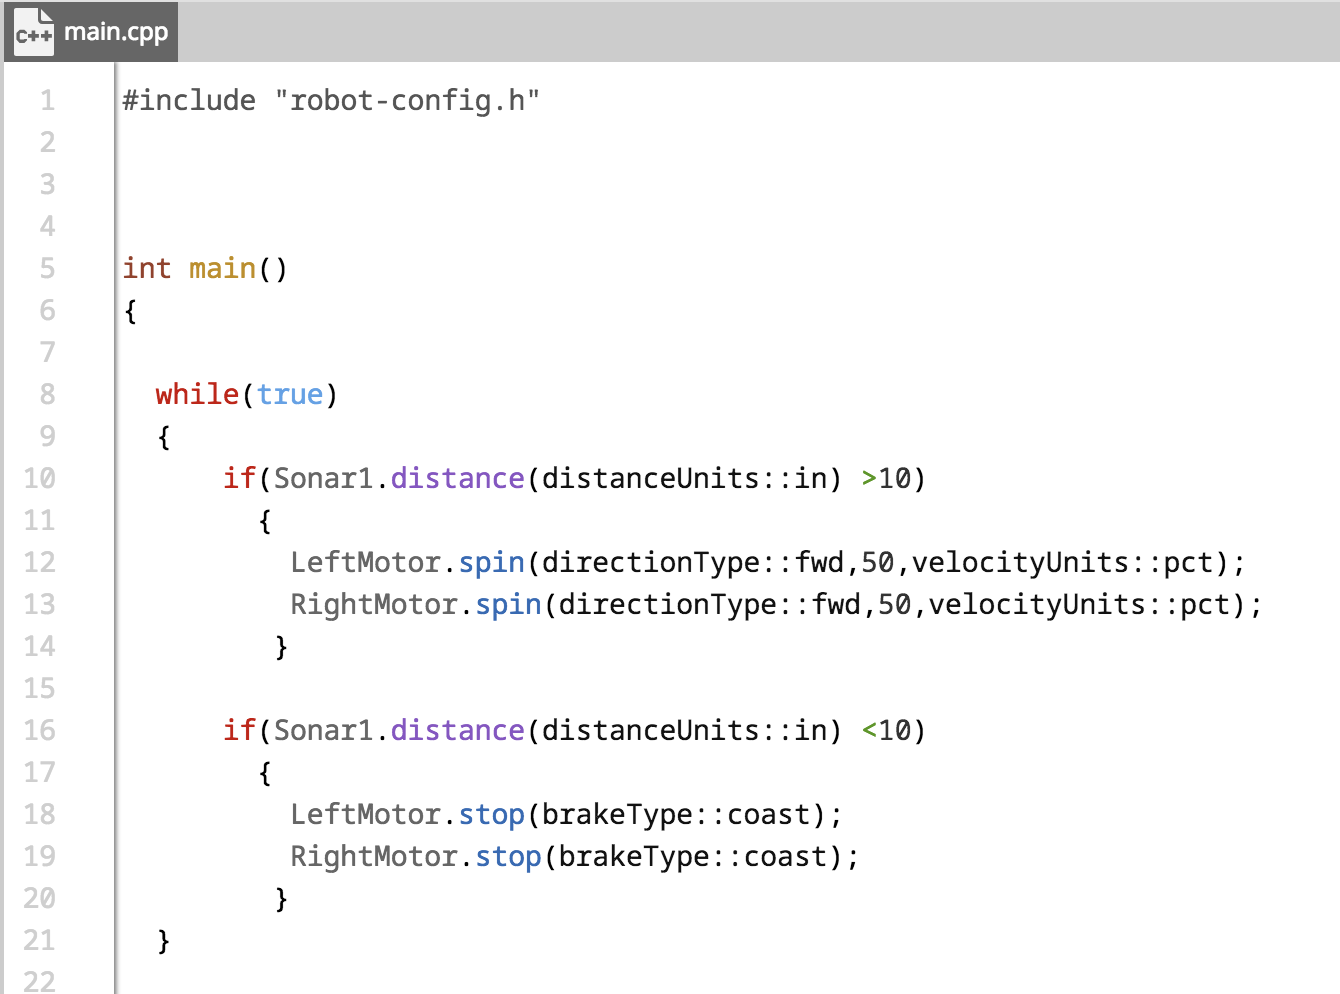
Help Ultrasonics While Loops Vex Coding Studio Tech Support Vex Forum
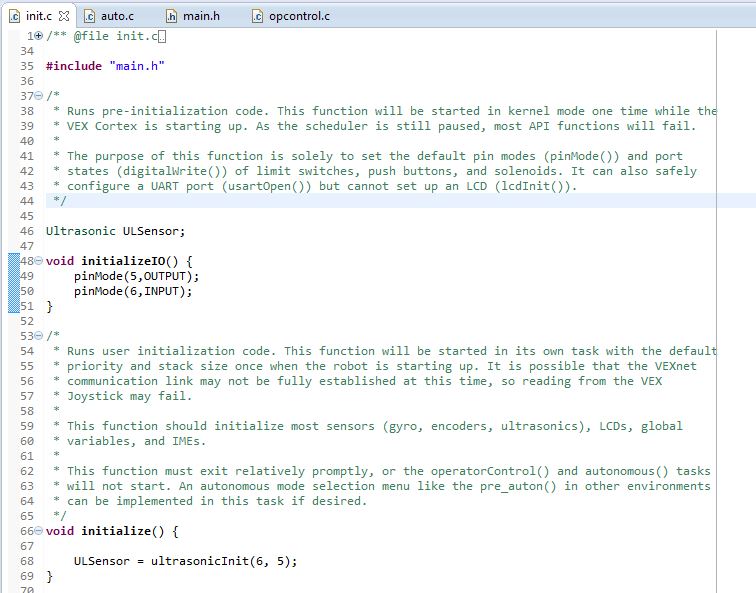
Ultrasonic Sensor Output Always 0 Vex V5 Technical Support Vex Forum
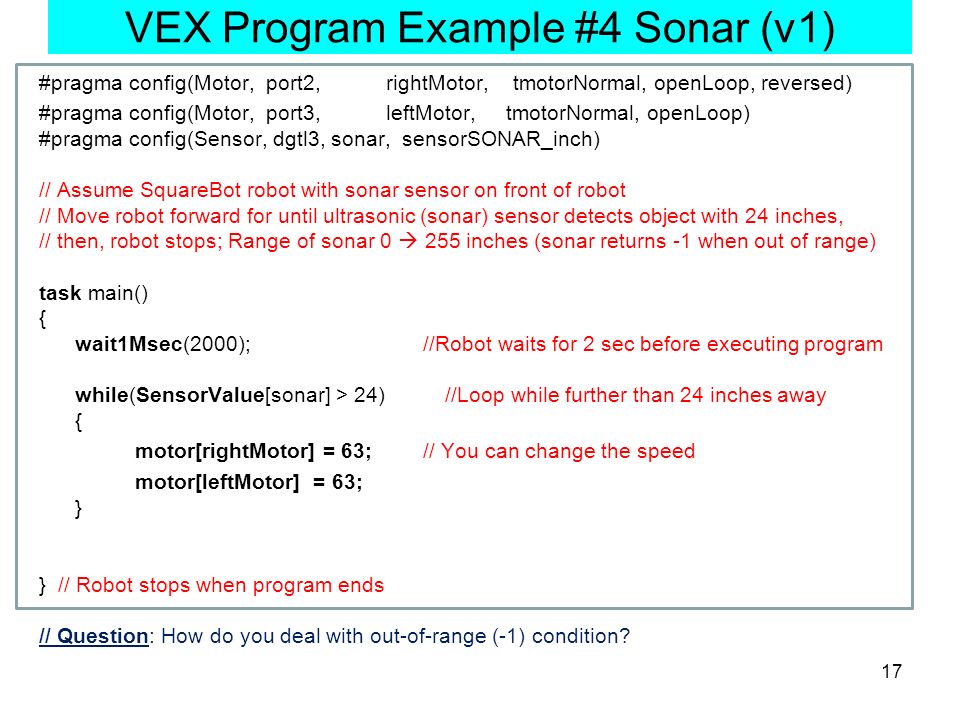
Programming Vex Cortex Robotics With Robotc Ppt Download

Using An Ultrasonic Sensor To Measure Distance Robotc Api Guide
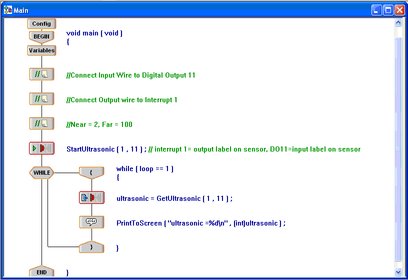
Ultrasonic Sensor Problem General Forum Vex Forum

Programming The Ultrasonic Sensor Youtube

In the pre autonomous section of the code robotc.
Vex sonar sensor code. This sensor is most often used in obstacle detection. 1 declare a variable that will store the data received by the sensor number of inches 2 call the startultrasonic x y function once only x interrupt port y digital output port 3 include variable getultrasonic x y in a loop in order to poll for values similar to using a. The inertial sensor needs to be paired with a programming language such as the vexcode v5 or vexcode pro v5 to create a user program for the v5 brain to utilize the sensor s readings to control the robot s behavior. A programming kit is needed to change the program in the vex controller.
It can detect objects at a range of up to 255 inches approximately 647 centimeters but this range can be limited in certain environments. A heading an amount of rotation a rate of. The vex robotics design system offers students an exciting platform for learning about areas rich with career opportunities spanning science technology engineering and math stem. The v5 brain in concert with a user program can be used to convert the inertial sensor readings into many measurements including.
Device emits a high frequency sound wave that alerts the robot to things in its path. Measure distances from 1 5in to 115in detect obstacles using high frequency sound waves create more autonomous function. Avoid obstacles and measure distances with the ultrasonic range finder. Programming the ultrasonic sensor 4 steps must be taken to use the sensor.
The sensor can be used to detect objects between 2 and 800 centimeters with a resolution of 1 centimeter. Enjoy the videos and music you love upload original content and share it all with friends family and the world on youtube. Also there is the code for reading the sensor values and returning the detected. Beyond science and engineering principles a vex robotics project encourages teamwork leadership and problem.
Urm37 v3 2 ultrasonic sensor in this tutorial you will find the information to connect the ultrasonic sensor to the arduino board or an arduino clone. The initialize tab for easyc users we added a few lines of code to say while the robot is disabled put the ultrasonic sensor value to the lcd screen the if the robot is disabled part is critical. Set the sensor type to sonar set the type of the sensor to sonar another name for the ultrasonic rangefinder because it uses sonar sound waves to measure distance. Otherwise it will never break out of the while loop when autonomous starts.
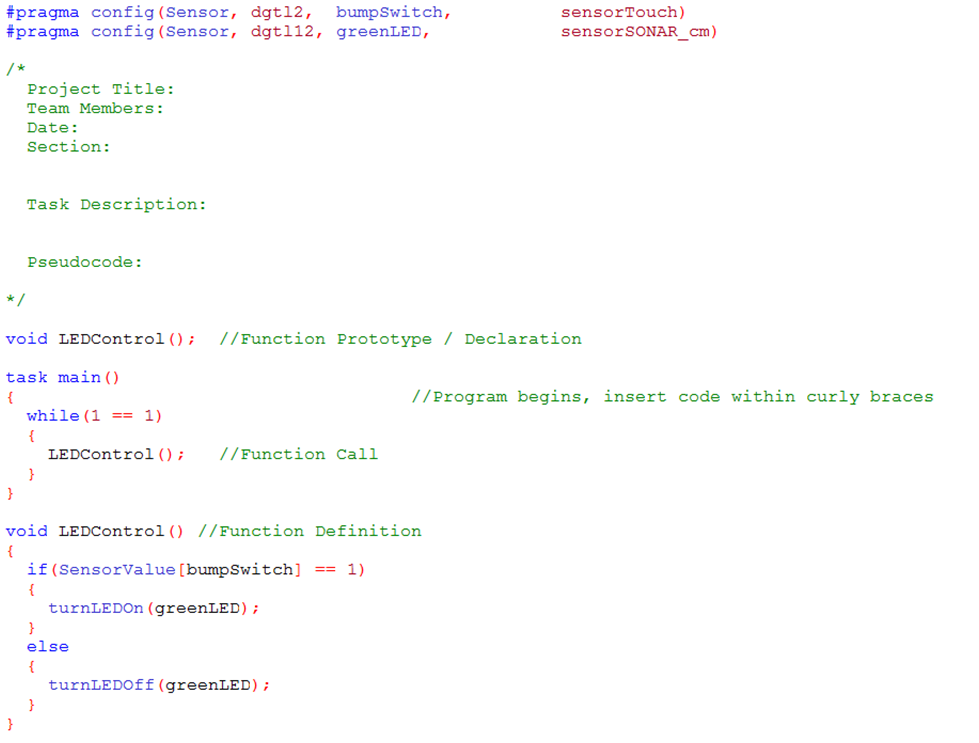
Basic Programming Alex S Web Page

Sensor Coding Tutorial Youtube

Vex Ultrasonic Sensors Youtube

Team B Journal Cooper Vex Robotics

Using An Ultrasonic Sensor To Detect And Avoid Walls Robotc Api Guide
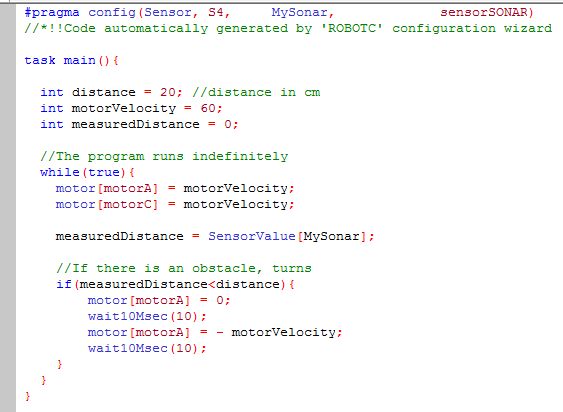
Introduction To Programming Nxt Robots In C With Robotc

Vision Sensor Vex C Knowledge Base

Using The Vex Lcd Screen And Robotc Remote Screen Part 1 At Robotc Net Blog
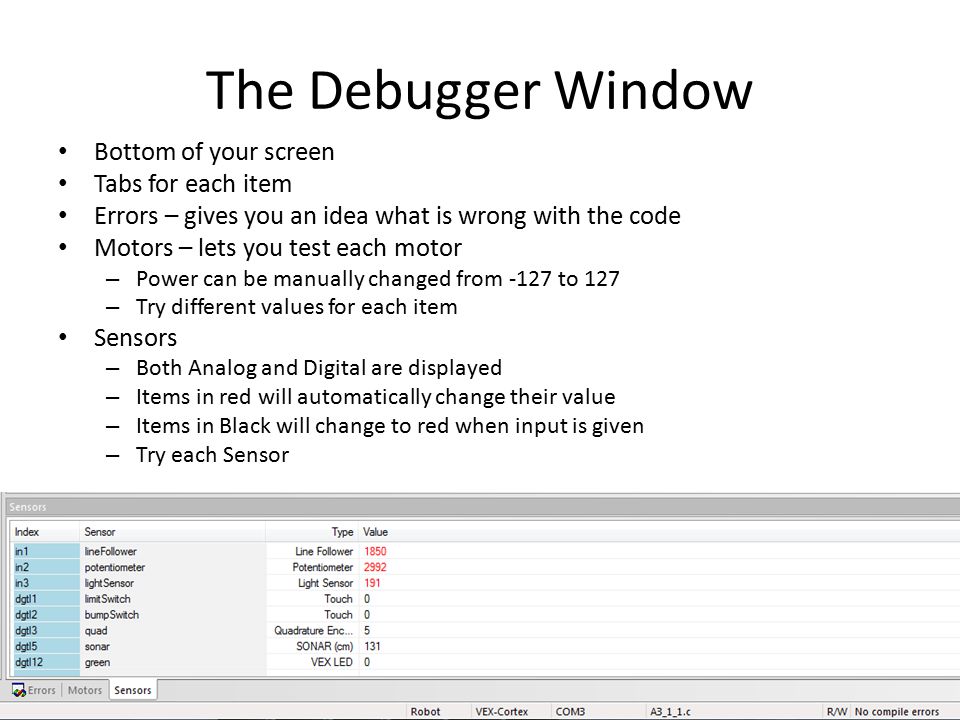
Vex Robotc Session Ppt Download

Vex Iq Robotc Touch Sensor Youtube
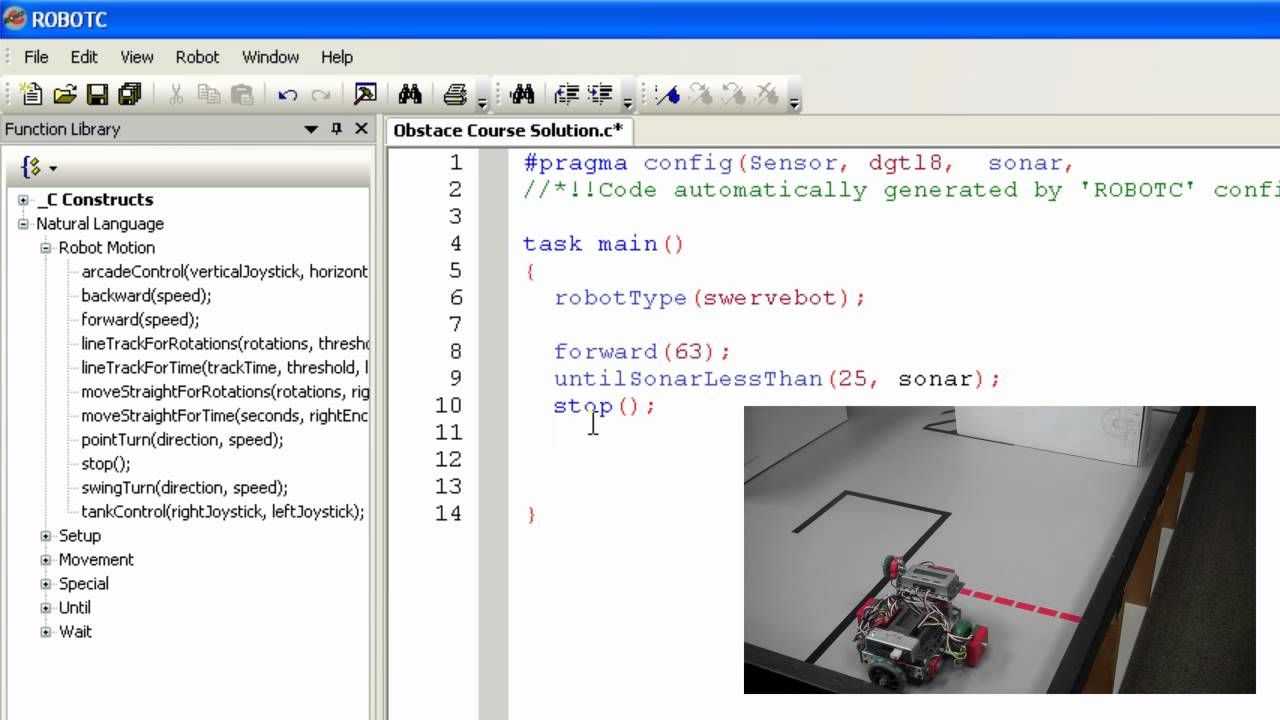
Robotc Net Robotc Natural Language
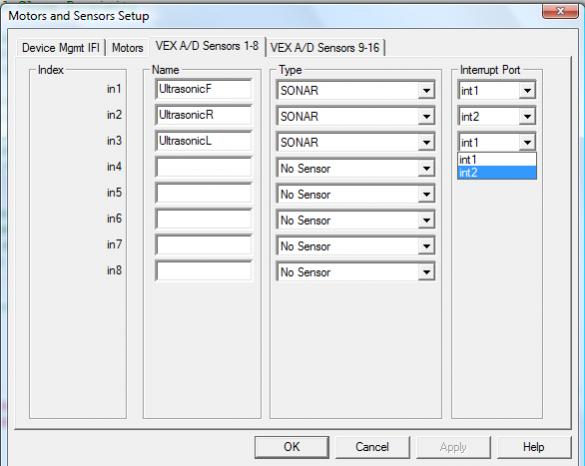
Need 3 Sonars Unofficial Tech Support Vex Forum

Team D Journal

